02
Initial configuration and Jacobian The Jacobian is:
J ( s , t ) = [ ∂ x ∂ s ∂ y ∂ s ∂ x ∂ t ∂ y ∂ t ] = H ( s , t ) [ x 1 y 1 x 2 y 2 x 3 y 3 x 4 y 4 ] \htmlClass{fea-math-bold-italic}{\boldsymbol{J}}(s,t)=\begin{bmatrix}\dfrac{\partial x}{\partial s}&\dfrac{\partial y}{\partial s}\\[4pt]\dfrac{\partial x}{\partial t}&\dfrac{\partial y}{\partial t}\end{bmatrix}=\htmlClass{fea-math-bold-italic}{\boldsymbol{H}}(s,t)\begin{bmatrix}x_1&y_1\\x_2&y_2\\x_3&y_3\\x_4&y_4\end{bmatrix} J ( s , t ) = ∂ s ∂ x ∂ t ∂ x ∂ s ∂ y ∂ t ∂ y = H ( s , t ) x 1 x 2 x 3 x 4 y 1 y 2 y 3 y 4 H ( s , t ) = 1 4 [ 1 + t − ( 1 + t ) − ( 1 − t ) 1 − t 1 + s 1 − s − ( 1 − s ) − ( 1 + s ) ] \htmlClass{fea-math-bold-italic}{\boldsymbol{H}}(s,t)=\frac14\begin{bmatrix}1+t&-(1+t)&-(1-t)&1-t\\1+s&1-s&-(1-s)&-(1+s)\end{bmatrix} H ( s , t ) = 4 1 [ 1 + t 1 + s − ( 1 + t ) 1 − s − ( 1 − t ) − ( 1 − s ) 1 − t − ( 1 + s ) ] x 1 , … , x 4 x_1,\ldots,x_4 x 1 , … , x 4 y 1 , … , y 4 y_1,\ldots,y_4 y 1 , … , y 4
d A = ∣ d e t J ∣ d s d t dA=\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol{J}}\right|\,ds\,dt d A = ∣ det J ∣ d s d t The derivatives of the shape functions with respect to the initial Cartesian coordinates are obtained using the inverse Jacobian; see Section 9.4 :
b = J − 1 H = [ b 11 b 12 b 13 b 14 b 21 b 22 b 23 b 24 ] \htmlClass{fea-math-bold-italic}{\boldsymbol{b}}=\htmlClass{fea-math-bold-italic}{\boldsymbol{J}}^{-1}\htmlClass{fea-math-bold-italic}{\boldsymbol{H}}=\begin{bmatrix}b_{11}&b_{12}&b_{13}&b_{14}\\b_{21}&b_{22}&b_{23}&b_{24}\end{bmatrix} b = J − 1 H = [ b 11 b 21 b 12 b 22 b 13 b 23 b 14 b 24 ] The four displacement-derivative relations are:
The element nodal displacement vector is:
u e l = { u 1 v 1 u 2 v 2 u 3 v 3 u 4 v 4 } \htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}=\begin{Bmatrix}u_1\\v_1\\u_2\\v_2\\u_3\\v_3\\u_4\\v_4\end{Bmatrix} u e l = ⎩ ⎨ ⎧ u 1 v 1 u 2 v 2 u 3 v 3 u 4 v 4 ⎭ ⎬ ⎫ 03
Green–Lagrange strains The two-dimensional Green–Lagrange strain components are:
ε x = ∂ u ∂ x + 1 2 ( ∂ u ∂ x ) 2 + 1 2 ( ∂ v ∂ x ) 2 \varepsilon_x=\frac{\partial u}{\partial x}+\frac12\left(\frac{\partial u}{\partial x}\right)^2+\frac12\left(\frac{\partial v}{\partial x}\right)^2 ε x = ∂ x ∂ u + 2 1 ( ∂ x ∂ u ) 2 + 2 1 ( ∂ x ∂ v ) 2 ε y = ∂ v ∂ y + 1 2 ( ∂ u ∂ y ) 2 + 1 2 ( ∂ v ∂ y ) 2 \varepsilon_y=\frac{\partial v}{\partial y}+\frac12\left(\frac{\partial u}{\partial y}\right)^2+\frac12\left(\frac{\partial v}{\partial y}\right)^2 ε y = ∂ y ∂ v + 2 1 ( ∂ y ∂ u ) 2 + 2 1 ( ∂ y ∂ v ) 2 γ x y = ∂ u ∂ y + ∂ v ∂ x + ∂ u ∂ x ∂ u ∂ y + ∂ v ∂ x ∂ v ∂ y \gamma_{xy}=\frac{\partial u}{\partial y}+\frac{\partial v}{\partial x}+\frac{\partial u}{\partial x}\frac{\partial u}{\partial y}+\frac{\partial v}{\partial x}\frac{\partial v}{\partial y} γ x y = ∂ y ∂ u + ∂ x ∂ v + ∂ x ∂ u ∂ y ∂ u + ∂ x ∂ v ∂ y ∂ v After introducing the displacement interpolation, the strains become:
ε x = B u x u e l + 1 2 u e l T G x u e l \varepsilon_x=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}+\frac12\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_x\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el} ε x = B u x u e l + 2 1 u e l T G x u e l ε y = B v y u e l + 1 2 u e l T G y u e l \varepsilon_y=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}+\frac12\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_y\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el} ε y = B v y u e l + 2 1 u e l T G y u e l γ x y = ( B u y + B v x ) u e l + 1 2 u e l T G x y u e l \gamma_{xy}=(\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x})\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}+\frac12\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_{xy}\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el} γ x y = ( B u y + B v x ) u e l + 2 1 u e l T G x y u e l The symmetric 8 × 8 8\times8 8 × 8
G x = B u x T B u x + B v x T B v x \htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_x=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x} G x = B u x T B u x + B v x T B v x G y = B u y T B u y + B v y T B v y \htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_y=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y} G y = B u y T B u y + B v y T B v y G x y = B u x T B u y + B u y T B u x + B v x T B v y + B v y T B v x \htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_{xy}=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x} G x y = B u x T B u y + B u y T B u x + B v x T B v y + B v y T B v x 04
Strain-displacement matrix The matrix B \htmlClass{fea-math-bold-italic}{\boldsymbol B} B
d ε e l = B d u e l d\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}_{el}=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}\,d\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el} d ε e l = B d u e l B = ∂ ε e l ∂ u e l \htmlClass{fea-math-bold-italic}{\boldsymbol B}=\frac{\partial\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}_{el}}{\partial\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}} B = ∂ u e l ∂ ε e l Component by component:
d ε x = ( B u x + u e l T G x ) d u e l d\varepsilon_x=\left(\htmlClass{fea-math-bold-italic}{\boldsymbol B}_{u_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_x\right)d\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el} d ε x = ( B u x + u e l T G x ) d u e l d ε y = ( B v y + u e l T G y ) d u e l d\varepsilon_y=\left(\htmlClass{fea-math-bold-italic}{\boldsymbol B}_{v_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_y\right)d\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el} d ε y = ( B v y + u e l T G y ) d u e l d γ x y = ( B u y + B v x + u e l T G x y ) d u e l d\gamma_{xy}=\left(\htmlClass{fea-math-bold-italic}{\boldsymbol B}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_{v_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy}\right)d\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el} d γ x y = ( B u y + B v x + u e l T G x y ) d u e l { d ε x d ε y d γ x y } = [ B u x + u e l T G x B v y + u e l T G y B u y + B v x + u e l T G x y ] ⏟ B d u e l \begin{Bmatrix}d\varepsilon_x\\d\varepsilon_y\\d\gamma_{xy}\end{Bmatrix}=\underbrace{\begin{bmatrix}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_x\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_y\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_{xy}\end{bmatrix}}_{\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}}d\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el} ⎩ ⎨ ⎧ d ε x d ε y d γ x y ⎭ ⎬ ⎫ = B B u x + u e l T G x B v y + u e l T G y B u y + B v x + u e l T G x y d u e l The matrix is split into a constant part, identical to linear theory, and a nonlinear displacement-dependent part:
B ( u e l ) = B 0 + B L ( u e l ) \htmlClass{fea-math-bold-italic}{\boldsymbol{B}}(\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el})=\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_0+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_L(\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}) B ( u e l ) = B 0 + B L ( u e l ) [ B u x + u e l T G x B v y + u e l T G y B u y + B v x + u e l T G x y ] ⏟ B = [ B u x B v y B u y + B v x ] ⏟ B 0 + [ u e l T G x u e l T G y u e l T G x y ] ⏟ B L \underbrace{\begin{bmatrix}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_x\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_y\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x}+\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_{xy}\end{bmatrix}}_{\htmlClass{fea-math-bold-italic}{\boldsymbol B}}=\underbrace{\begin{bmatrix}\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_x}\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_y}\\\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{u_y}+\htmlClass{fea-math-bold-italic}{\boldsymbol{B}}_{v_x}\end{bmatrix}}_{\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0}+\underbrace{\begin{bmatrix}\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_x\\\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_y\\\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{G}}_{xy}\end{bmatrix}}_{\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L} B B u x + u e l T G x B v y + u e l T G y B u y + B v x + u e l T G x y = B 0 B u x B v y B u y + B v x + B L u e l T G x u e l T G y u e l T G x y B 0 \htmlClass{fea-math-bold-italic}{\boldsymbol B}_0 B 0 B L \htmlClass{fea-math-bold-italic}{\boldsymbol B}_L B L
05
Potential energy and Gauss quadrature The total potential energy is:
Π = U + V = 1 2 A e l = 1 n e l ( ∫ A e l h ε T σ d A ) − u T F \mathit{\Pi}=U+V=\frac12\mathcal{A}_{el=1}^{n_{el}}\left(\int_{A_{el}}h\,\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,dA\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{F}} Π = U + V = 2 1 A e l = 1 n e l ( ∫ A e l h ε T σ d A ) − u T F Here, V = − u T F V=-\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol F} V = − u T F u \htmlClass{fea-math-bold-italic}{\boldsymbol u} u F \htmlClass{fea-math-bold-italic}{\boldsymbol F} F
Π = U + V = 1 2 A e l = 1 n e l ( ∫ − 1 1 ∫ − 1 1 h ( s , t ) ε T ( s , t ) σ ( s , t ) ∣ d e t J ( s , t ) ∣ d s d t ) − u T F \mathit{\Pi}=U+V=\frac12\mathcal{A}_{el=1}^{n_{el}}\left(\int_{-1}^{1}\int_{-1}^{1}h(s,t)\,\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}^{T}(s,t)\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}(s,t)\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}(s,t)\right|\,ds\,dt\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol F} Π = U + V = 2 1 A e l = 1 n e l ( ∫ − 1 1 ∫ − 1 1 h ( s , t ) ε T ( s , t ) σ ( s , t ) ∣ det J ( s , t ) ∣ d s d t ) − u T F Using 2 × 2 2\times2 2 × 2
Π = U + V = 1 2 A e l = 1 n e l ( ∑ n G h ( s G , t G ) ε T ( s G , t G ) σ ( s G , t G ) ∣ d e t J ( s G , t G ) ∣ ) − u T F \mathit{\Pi}=U+V=\frac12\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h(s_G,t_G)\,\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}^{T}(s_G,t_G)\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}(s_G,t_G)\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}(s_G,t_G)\right|\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol F} Π = U + V = 2 1 A e l = 1 n e l ( n G ∑ h ( s G , t G ) ε T ( s G , t G ) σ ( s G , t G ) ∣ det J ( s G , t G ) ∣ ) − u T F The integration uses four Gauss points, two in each natural-coordinate direction. For the 2 × 2 2\times2 2 × 2
∑ n G E ( s G , t G ) = E ( 1 3 , 1 3 ) + E ( 1 3 , − 1 3 ) + E ( − 1 3 , 1 3 ) + E ( − 1 3 , − 1 3 ) \sum_{n_G}E(s_G,t_G)=E\left(\frac{1}{\sqrt3},\frac{1}{\sqrt3}\right)+E\left(\frac{1}{\sqrt3},-\frac{1}{\sqrt3}\right)+E\left(-\frac{1}{\sqrt3},\frac{1}{\sqrt3}\right)+E\left(-\frac{1}{\sqrt3},-\frac{1}{\sqrt3}\right) n G ∑ E ( s G , t G ) = E ( 3 1 , 3 1 ) + E ( 3 1 , − 3 1 ) + E ( − 3 1 , 3 1 ) + E ( − 3 1 , − 3 1 ) where the integrand is:
E ( s , t ) = h ( s , t ) ε T ( s , t ) σ ( s , t ) ∣ d e t J ( s , t ) ∣ E(s,t)=h(s,t)\,\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}^{T}(s,t)\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}(s,t)\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}(s,t)\right| E ( s , t ) = h ( s , t ) ε T ( s , t ) σ ( s , t ) ∣ det J ( s , t ) ∣ 06
Virtual work and equilibrium The virtual-work equation is:
δ Π = A e l = 1 n e l ( ∑ n G h δ ε T σ ∣ d e t J ∣ ) − δ u T F = 0 \delta\mathit{\Pi}=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)-\delta\htmlClass{fea-math-bold-italic}{\boldsymbol{u}}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol F}=0 δ Π = A e l = 1 n e l ( n G ∑ h δ ε T σ ∣ det J ∣ ) − δ u T F = 0 This relation holds for every geometrically admissible virtual displacement field. Therefore, the nonlinear equilibrium system is:
Ψ ( u ) = A e l = 1 n e l ( ∑ n G h B T σ ∣ d e t J ∣ ) − F = 0 \htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}(\htmlClass{fea-math-bold-italic}{\boldsymbol u})=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol F}=\htmlClass{fea-math-bold-italic}{\boldsymbol0} Ψ ( u ) = A e l = 1 n e l ( n G ∑ h B T σ ∣ det J ∣ ) − F = 0 Equivalently, using the split of the strain-displacement matrix:
Ψ ( u ) = A e l = 1 n e l ( ∑ n G h [ B 0 T + B L T ( u e l ) ] σ ∣ d e t J ∣ ) − F = 0 \htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}(\htmlClass{fea-math-bold-italic}{\boldsymbol u})=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\left[\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0^{T}+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L^{T}(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el})\right]\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol F}=\htmlClass{fea-math-bold-italic}{\boldsymbol0} Ψ ( u ) = A e l = 1 n e l ( n G ∑ h [ B 0 T + B L T ( u e l ) ] σ ∣ det J ∣ ) − F = 0 07
Tangent stiffness matrix The first variation of the equilibrium residual is:
δ Ψ = A e l = 1 n e l ( ∑ n G h δ B T σ ∣ d e t J ∣ ) + A e l = 1 n e l ( ∑ n G h B T δ σ ∣ d e t J ∣ ) = K T δ u \delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)+\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)=\htmlClass{fea-math-bold-italic}{\boldsymbol{K}}_T\delta\htmlClass{fea-math-bold-italic}{\boldsymbol u} δ Ψ = A e l = 1 n e l ( n G ∑ h δ B T σ ∣ det J ∣ ) + A e l = 1 n e l ( n G ∑ h B T δ σ ∣ det J ∣ ) = K T δ u Using B = B 0 + B L ( u e l ) \htmlClass{fea-math-bold-italic}{\boldsymbol B}=\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}) B = B 0 + B L ( u e l )
δ Ψ = A e l = 1 n e l ( ∑ n G h δ [ B 0 T + B L T ( u e l ) ] σ ∣ d e t J ∣ ) + A e l = 1 n e l ( ∑ n G h [ B 0 T + B L T ( u e l ) ] δ σ ∣ d e t J ∣ ) = K T δ u \delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\delta\left[\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0^{T}+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L^{T}(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el})\right]\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)+\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\left[\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0^{T}+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L^{T}(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el})\right]\delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)=\htmlClass{fea-math-bold-italic}{\boldsymbol{K}}_T\delta\htmlClass{fea-math-bold-italic}{\boldsymbol u} δ Ψ = A e l = 1 n e l ( n G ∑ h δ [ B 0 T + B L T ( u e l ) ] σ ∣ det J ∣ ) + A e l = 1 n e l ( n G ∑ h [ B 0 T + B L T ( u e l ) ] δ σ ∣ det J ∣ ) = K T δ u Because B 0 \htmlClass{fea-math-bold-italic}{\boldsymbol B}_0 B 0
δ B = δ ( B 0 + B L ) = δ B L \delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}=\delta(\htmlClass{fea-math-bold-italic}{\boldsymbol B}_0+\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L)=\delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L δ B = δ ( B 0 + B L ) = δ B L Taking into account that G x \htmlClass{fea-math-bold-italic}{\boldsymbol G}_x G x G y \htmlClass{fea-math-bold-italic}{\boldsymbol G}_y G y G x y \htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy} G x y 8 × 8 8\times8 8 × 8
δ B T σ = δ B L T σ = δ ( [ ( u e l T G x ) T ( u e l T G y ) T ( u e l T G x y ) T ] ) σ \delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}=\delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}_L^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}=\delta\left(\begin{bmatrix}\left(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_x\right)^{T}\\\left(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_y\right)^{T}\\\left(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy}\right)^{T}\end{bmatrix}\right)\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}} δ B T σ = δ B L T σ = δ ( u e l T G x ) T ( u e l T G y ) T ( u e l T G x y ) T σ δ B T σ = ( σ x G x + σ y G y + τ x y G x y ) δ u e l \delta\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}=\left(\sigma_x\htmlClass{fea-math-bold-italic}{\boldsymbol G}_x+\sigma_y\htmlClass{fea-math-bold-italic}{\boldsymbol G}_y+\tau_{xy}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy}\right)\delta\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el} δ B T σ = ( σ x G x + σ y G y + τ x y G x y ) δ u e l The stress variation is:
δ σ = D δ ε = D B δ u e l \delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}=\htmlClass{fea-math-bold-italic}{\boldsymbol D}\,\delta\htmlClass{fea-math-bold-italic}{\boldsymbol{\varepsilon}}=\htmlClass{fea-math-bold-italic}{\boldsymbol D}\htmlClass{fea-math-bold-italic}{\boldsymbol B}\,\delta\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el} δ σ = D δ ε = D B δ u e l Consequently, the global tangent stiffness matrix is:
K T = A e l = 1 n e l ( ∑ n G h [ σ x G x + σ y G y + τ x y G x y ] ∣ d e t J ∣ ) + A e l = 1 n e l ( ∑ n G h B T D B ∣ d e t J ∣ ) \htmlClass{fea-math-bold-italic}{\boldsymbol{K}}_T=\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\left[\sigma_x\htmlClass{fea-math-bold-italic}{\boldsymbol G}_x+\sigma_y\htmlClass{fea-math-bold-italic}{\boldsymbol G}_y+\tau_{xy}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy}\right]\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right)+\mathcal{A}_{el=1}^{n_{el}}\left(\sum_{n_G}h\,\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol D}\htmlClass{fea-math-bold-italic}{\boldsymbol B}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right|\right) K T = A e l = 1 n e l ( n G ∑ h [ σ x G x + σ y G y + τ x y G x y ] ∣ det J ∣ ) + A e l = 1 n e l ( n G ∑ h B T D B ∣ det J ∣ ) The tangent stiffness matrix contains two contributions: the material stiffness and the geometric (stress-dependent) stiffness. For one finite element:
k e l = ∑ n G h ( σ x G x + σ y G y + τ x y G x y + B T D B ) ∣ d e t J ∣ \htmlClass{fea-math-bold-italic}{\boldsymbol k}_{el}=\sum_{n_G}h\left(\sigma_x\htmlClass{fea-math-bold-italic}{\boldsymbol G}_x+\sigma_y\htmlClass{fea-math-bold-italic}{\boldsymbol G}_y+\tau_{xy}\htmlClass{fea-math-bold-italic}{\boldsymbol G}_{xy}+\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol D}\htmlClass{fea-math-bold-italic}{\boldsymbol B}\right)\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right| k e l = n G ∑ h ( σ x G x + σ y G y + τ x y G x y + B T D B ) ∣ det J ∣ The equilibrium system can also be written in terms of the element internal force vectors:
Ψ ( u ) = A e l = 1 n e l ( f e l ) − F = 0 \htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}(\htmlClass{fea-math-bold-italic}{\boldsymbol u})=\mathcal{A}_{el=1}^{n_{el}}\left(\htmlClass{fea-math-bold-italic}{\boldsymbol f}_{el}\right)-\htmlClass{fea-math-bold-italic}{\boldsymbol F}=\htmlClass{fea-math-bold-italic}{\boldsymbol0} Ψ ( u ) = A e l = 1 n e l ( f e l ) − F = 0 f e l = ∑ n G h B T σ ∣ d e t J ∣ \htmlClass{fea-math-bold-italic}{\boldsymbol f}_{el}=\sum_{n_G}h\,\htmlClass{fea-math-bold-italic}{\boldsymbol B}^{T}\htmlClass{fea-math-bold-italic}{\boldsymbol{\sigma}}\,\left|\mathop{\mathit{det}}\htmlClass{fea-math-bold-italic}{\boldsymbol J}\right| f e l = n G ∑ h B T σ ∣ det J ∣ The element tangent stiffness matrix is the derivative of the element internal force vector:
k e l = ∂ f e l ∂ u e l \htmlClass{fea-math-bold-italic}{\boldsymbol k}_{el}=\frac{\partial\htmlClass{fea-math-bold-italic}{\boldsymbol f}_{el}}{\partial\htmlClass{fea-math-bold-italic}{\boldsymbol u}_{el}} k e l = ∂ u e l ∂ f e l 08
Newton–Raphson solution At Newton–Raphson iteration i i i
Δ u ( i ) = − ( K T ( i ) ) − 1 Ψ ( i ) \mathit{\Delta}\htmlClass{fea-math-bold-italic}{\boldsymbol u}^{(i)}=-\left(\htmlClass{fea-math-bold-italic}{\boldsymbol K}_T^{(i)}\right)^{-1}\htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}^{(i)} Δ u ( i ) = − ( K T ( i ) ) − 1 Ψ ( i ) u ( i + 1 ) = u ( i ) + Δ u ( i ) \htmlClass{fea-math-bold-italic}{\boldsymbol u}^{(i+1)}=\htmlClass{fea-math-bold-italic}{\boldsymbol u}^{(i)}+\mathit{\Delta}\htmlClass{fea-math-bold-italic}{\boldsymbol u}^{(i)} u ( i + 1 ) = u ( i ) + Δ u ( i ) Ψ ( i ) = Ψ ( u i ) \htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}^{(i)}=\htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}\left(\htmlClass{fea-math-bold-italic}{\boldsymbol u}_i\right) Ψ ( i ) = Ψ ( u i ) The element internal-force vectors f e l \htmlClass{fea-math-bold-italic}{\boldsymbol f}_{el} f e l k e l \htmlClass{fea-math-bold-italic}{\boldsymbol k}_{el} k e l Ψ ( i ) \htmlClass{fea-math-bold-italic}{\boldsymbol{\mathit{\Psi}}}^{(i)} Ψ ( i ) K T ( i ) \htmlClass{fea-math-bold-italic}{\boldsymbol K}_T^{(i)} K T ( i )
ϵ = Δ u T Δ u n \epsilon=\sqrt{\frac{\mathit{\Delta}\htmlClass{fea-math-bold-italic}{\boldsymbol u}^{T}\mathit{\Delta}\htmlClass{fea-math-bold-italic}{\boldsymbol u}}{n}} ϵ = n Δ u T Δ u where n n n
Important remark #1 The Total Lagrangian formulation presented here is not based on an incremental strain approximation. The equilibrium equations are written directly with respect to the initial configuration. Therefore, the accuracy of the formulation itself does not depend on the number of load steps. For problems with moderate nonlinearity, a single load step may be sufficient, provided that the Newton–Raphson iterations converge. Additional load steps may nevertheless be useful to improve convergence in more strongly nonlinear problems.
09
Example and numerical results The cantilever beam has length L = 400 m m L=400\ \mathit{mm} L = 400 mm 5 m m 5\ \mathit{mm} 5 mm 20 m m 20\ \mathit{mm} 20 mm E = 1000 M P a E=1000\ \mathit{MPa} E = 1000 MPa ν = 0.3 \nu=0.3 ν = 0.3 F = 100 N F=100\ \mathit{N} F = 100 N
The mesh has 120 quadrilateral elements along the beam and 16 elements through its height: 1,920 isoparametric 4-node quadrilateral finite elements and 2,057 nodes.
Figure 1. Horizontal displacement u u u Figure 2. Vertical displacement v v v Figure 3. Green–Lagrange axial strain ε x \varepsilon_x ε x Figure 4. Second Piola–Kirchhoff normal stress σ x \sigma_x σ x Figure 5. Von Mises stress σ V M \sigma_{\mathit{VM}} σ VM The MATLAB and ANSYS results are in very good agreement.
10
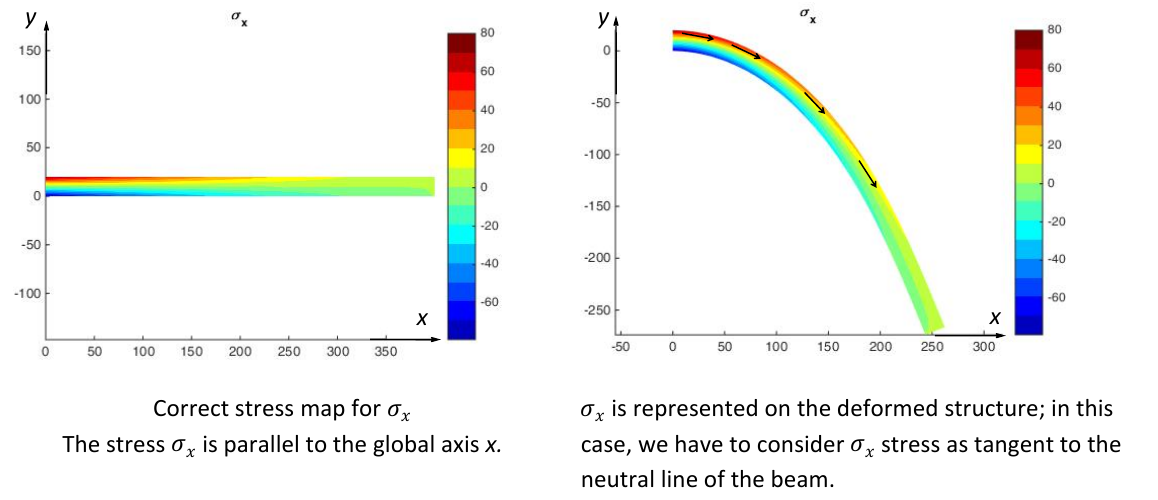
Stress-map interpretation Important remark #2 In the Total Lagrangian formulation, strains and stresses are referred to the initial undeformed configuration. Therefore, the mathematically consistent stress map is the one represented on the initial geometry.
For a more intuitive visualization, the same second Piola–Kirchhoff stresses may also be represented on the deformed geometry. In this representation, the material directions rotate together with the finite elements; therefore, the x x x
Cauchy stresses are defined in the current configuration. When strains are small, their values referred to the corresponding local, rotated material directions are very close to the second Piola–Kirchhoff stresses. The distinction becomes important when comparing stress components expressed in different reference frames.
This topic will be discussed in a later chapter.
Figure 6. Second Piola–Kirchhoff normal stress represented on the initial configuration and, for intuitive visualization, on the deformed geometry. The original explanatory arrows and labels are preserved.PREVIOUS SECTION ← 12.1. CST Finite Element NEXT SECTION 12.3. Isoparametric 8-Node Quadrilateral Finite Element →